Aerospace Engineering · University of Bath · Year 2
I turn engineering problems into things that ship.
Second-year aerospace engineer at Bath. First author on a battery machine-learning paper, co-founder and CTO of a live delivery platform, aerodynamics lead on a competition UAV. Twenty shipped, and counting.
Looking for a 2027/28 placement year in aerospace, defence or wherever hard engineering meets software.
- First-author paper
- Winkit CTO
- UAV aero lead
- Fifth9 red team
- Drive-shaft design
- 20+ shipped
- 0.57%blind-test SOC error, first-author paper
- CTOco-founder, Winkit, live at winkit.uk
- 30%lift-to-drag gain, Team Bath Drones
- ~30PRs merged to production at Fifth9
- FirstYear 1, 73.8% average
- Python
- PyTorch
- NumPy
- three.js
- Autodesk Inventor
- MATLAB
- Arduino
- Stripe
- Playwright
- Apps Script
- Vercel
01 / Selected work
The work I would lead with.
Five builds that carry the most weight. The rest live further down.
Battery ML research · first author
Reading a battery's charge from sound.
Coulomb counting drifts and the voltage curve sits flat. So I taught an LSTM to read state of charge from ultrasound, tested blind on real drive cycles.
- 0.57% mean absolute error on a blind real-world Paris electric-bus cycle.
- 42% less error on US06 once ultrasound joins voltage, current and temperature.
- A fully blind protocol: one real vehicle recording held out of every step, model selection included.
Details
- US06: 1.36% down to 0.79%, better on all ten of ten seeds (p = 0.002).
- Blind Paris: 0.70% down to 0.57% for the same fusion, a 19% cut.
- Built from first principles: a NumPy network with hand-derived backpropagation and Adam, then PyTorch LSTM ablations over features and architectures.
First author · supervised by Dr Christopher Vagg and Rob Gray, Institute for Advanced Automotive Propulsion Systems
Code private until publication
Tap a bar for its mean, spread and seed count.
| Variant | Paris MAE | Paris seeds improved | US06 MAE | US06 seeds improved |
|---|---|---|---|---|
| VIT (baseline) | 0.70 ± 0.16 | n/a | 1.36 ± 0.13 | n/a |
| VIT + ToF | 0.69 ± 0.30 | 60% | 1.36 ± 0.10 | 40% |
| VIT + velocity | 1.02 ± 0.50 | 30% | 0.91 ± 0.15 | 100% |
| VIT + displacement | 0.67 ± 0.18 | 70% | 0.84 ± 0.09 | 100% |
| VIT + ToF + displacement | 0.57 ± 0.19 | 80% | 0.79 ± 0.09 | 100% |
| VIT + all ultrasonic + displacement | 0.75 ± 0.23 | 60% | 0.84 ± 0.08 | 100% |
| VIT + shuffled velocity (null control) | 0.70 ± 0.21 | 70% | 1.32 ± 0.16 | 70% |
Interactive state-of-charge view. 0.57% blind Paris error, 0.79% on US06.
Winkit · local food delivery · co-founder and CTO
A delivery platform, co-founded and built end to end.
Aggregators take 38 to 40% of a local kitchen's revenue. So three of us built our own, and I built and run the whole stack.
- £0 commission, 0 drivers to hire, 0 new hardware for the kitchen.
- Orders land on the kitchen's own system, live on two restaurant platforms.
- Live Stripe payments and a GPS driver app with shifts and real-time order state.
Details
- Card payments gated to each kitchen's real opening hours.
- Run lean on free tiers: gating a 24/7 database cron by opening hours cut compute burn by about 68%.
- Neon Postgres, Vercel functions and per-kitchen order adapters.
Co-founder and CTO · architecture, build and operations
One order, five stations: customer pays, the kitchen's own system, ready, dispatched, delivered.
Team Bath Drones · aerodynamics lead
Leading the aerodynamics of a competition UAV.
I run the aerodynamics on Team Bath Drones' design-and-make UAV: more lift for every unit of drag, on less structure.
- 30% lift-to-drag gain from an aerofoil trade study, Clark-Y against NACA 0015.
- 400g structural weight saving, delivered at the Critical Design Review.
- Co-led the tadpole fuselage and its CAD, then presented the CDR to the judges.
Aerodynamics division lead · University design team
Fifth9 · applied AI · red team and build
Attacking an enterprise AI platform, then helping ship it.
An agentic AI platform heading into regulated enterprise has to survive a determined adversary first. I play that adversary, then help ship.
- Red-teams the platform's agents end to end over MCP, plus acceptance testing before client demos.
- ~30 pull requests merged to production, from security fixes to new capabilities.
- One memory, four models: a user's context carried across four major AI models on a single key.
Details
- Shipped an internal code-search tool that maps the whole codebase.
- Invited back after a 2025 internship: a generative-AI product shipped in a five-day sprint and pitched to the directors.
Red team, UAT, MCP tooling and demo builds · Fifth9
Client work under NDA
Year 2 design · snowmobile drive shaft
From 20kW at the motor to 209Nm at the track.
An electric snowmobile puts 20kW through one shaft at -40°C. I own the loads, free-body diagrams and drive ratio, built as a live engine.
- 3.28:1 down to 209Nm at 915RPM, sized for 50km/h on a 290mm track sprocket.
- A symbolic loads engine: change one input and every reaction, moment and stress updates, with 39 automated checks.
- Final design locked: 431 stainless at a safety factor of 6.7, 4.35kg on Fenner Taper Lock hubs.
Details
- Critical section at the drive sprocket: 80.4Nm peak bending, bearing reactions of 590.6N and 1340.1N.
- Bearings sized for a 5200h life, about 285 million revolutions at shaft speed.
Pair design project, ME22007 · my lane: loads, FBDs, drive ratio and shaft torque
Explore the live design guide FBD, shear and bending explainer
Motor 3000RPM · 63.7Nm to 3.28:1 to Shaft 915RPM · 209Nm.
02 / More builds
Twenty shipped, and counting.
Hardware, client sites, a tutoring business, bots and data pipelines. Most started as an itch of my own, then got hardened until they were reliable.
-
HardwareCoursework · 76.6%
Silent looping render of a 5:1 epicyclic gearbox: the sun gear turns the planet gears inside a fixed ring gear and the planet carrier turns slowly as output.
Epicyclic gearbox
A 5:1 planetary gearbox, modelled, driven and rendered in Autodesk Inventor.
Drive-constrained from a projected base sketch so the gears always mesh, fitted with standard bearings and circlips (BS 292, ANSI B27.7M), and backed by GD&T drawings marked at 88%.
-
HardwareMechatronics coursework
Ultrasonic measurement system
An Arduino ranging rig calibrated to 1.0mm RMSE against a 4.3mm datasheet spec.
Moving-average filtering and least-squares calibration cut noise by 60%; I mapped the ±18° beam and built a variance-based motion-rejection alarm.
-
HardwareYear 1 team of 6
Ping-pong launcher
Authored the slider-crank concept the whole team's launcher was built on.
Chosen over five alternatives on a weighted decision matrix, then taken through full Inventor CAD inside a 380×180×300mm envelope and an £85 budget.
-
Web & clientFounder · live
Locus Tutors
I turned my own tutoring into an online maths agency, and wrote the software that runs it.
Stripe save-card billing and a password-gated admin CRM I built from scratch, monthly PDF progress reports generated from lesson recordings, PostHog attribution on every channel.
-
Web & clientDe facto CTO · live
Neetu's Crafts
A full storefront for a family craft business, run end to end.
Edge-cached Vercel read path, an Apps Script and Sheets backend, UPI deep-link payments instead of a gateway and automatic order emails.
-
Web & clientExternal client · live
Ruby's Rasoi
A live restaurant site, shipped for a real client.
Built to a non-technical owner's brief on a platform I did not choose, then handed over something they can run.
-
AutomationPrivate
LocaBot
Six Chrome sessions in parallel, grabbing tickets the instant they drop.
Driven over the DevTools Protocol and coordinated with asyncio, with staggered polling to stay under rate limits.
-
AutomationPrivate
BaianaBot
A ticket sniper that watches an API and checks out before a human can refresh.
Polls a live REST API, holds a persistent session and drives a Stripe checkout through sandboxed iframes, backed by a 150+ test suite.
-
AutomationLive · private
Earnings calendar
A self-maintaining calendar of earnings dates for a 44-stock watchlist.
Runs unattended on scheduled triggers and rewrites each event with the realised price reaction afterwards.
-
AutomationLive
TES resource engine
Turns exam specifications and past papers into typeset worked-solution packs.
Generated as LaTeX, compiled with tectonic and published to the TES marketplace.
-
AutomationLive · local
WhatsApp scheduler
Queue a message, and it sends itself at a sensible hour.
A local web UI and a self-restarting background worker with retry and backoff, standard library only.
-
DataPrivate
Family portfolio tracker
Nine accounts and 37 holdings in one self-reconciling dashboard.
Pulls live positions from the Trading 212 API, handles multi-currency pricing and failed feeds, and reconciles to the penny.
-
DataPersonal project
Poker tracker
A session tracker with real variance analytics.
Standard deviation, 95% confidence intervals, breakeven win rate and expected value per session, computed from the raw data.
-
DataPersonal project
Pool tracker
A scoring app for a custom multiplayer pool game.
Per-turn undo, persistent state and an all-time leaderboard on a serverless Sheets store.
-
DataPrivate
Cricket tracker
Play-Cricket scorecards scraped into a clean stats database.
A logged-in Playwright scraper with match-level de-duplication, which also migrated an old manual dataset across.
About
Second-year engineer, compulsive builder.
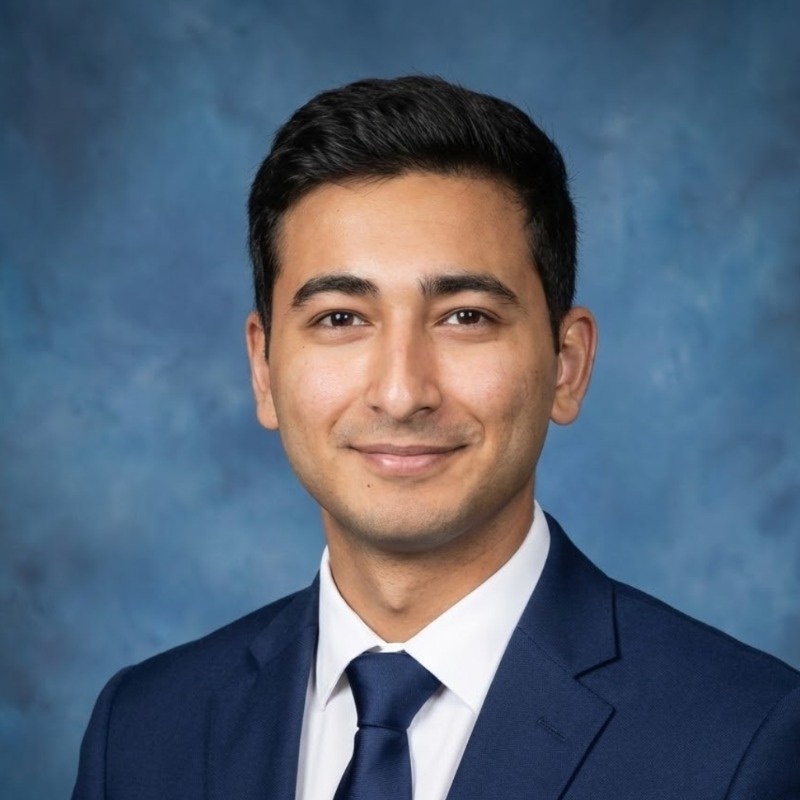
I am Aadi, a second-year Aerospace Engineering student at Bath with a First from Year 1 (73.8%). The fastest way I learn a system is to ship one.
The thread through all of it: software and machine learning pointed at real engineering. A battery that cannot report its own charge, a shaft carrying 209Nm through slush, a kitchen that should not need a second tablet.
- University
- University of Bath · Aerospace Engineering with Placement
- Placement window
- 2027/28
- Based in
- Bath, UK
Get in touch
Building something where this fits?
I am looking for a 2027/28 placement year in industry, and I am always up for a conversation about hard engineering, machine learning or anything on this page.